Publications

2027
Tilo clearing a cluttered bin
Reactive Control for Cluttered-Scene Non-Prehensile Manipulation
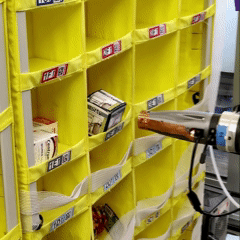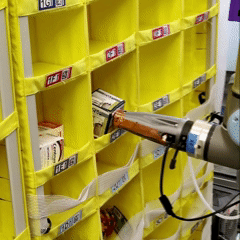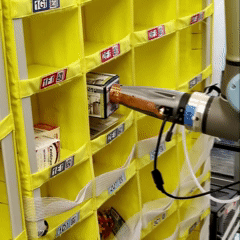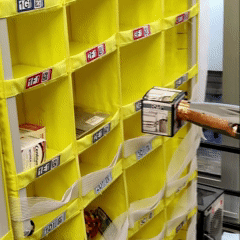
TBA · Major Robotics Conference 2027
2027
TactileSuction demo
TactileSuction: A smart suction cup
TBA · Major Robotics Conference 2027
2026
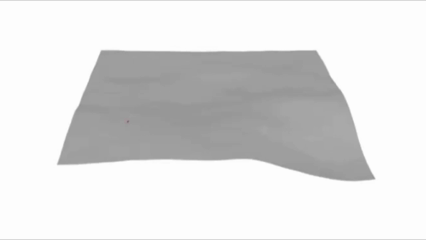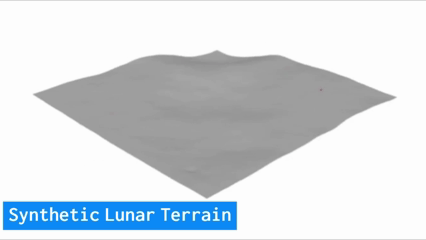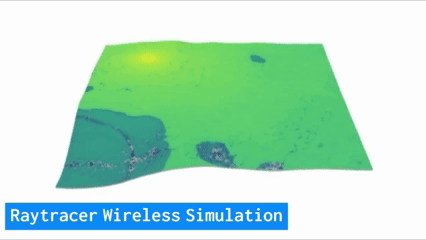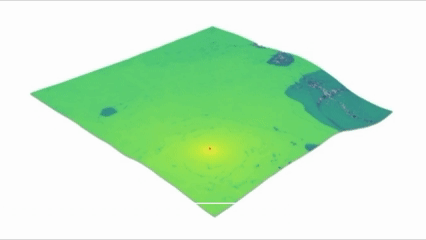
Predicted radio map over lunar terrain
RadioLunaDiff: Estimation of Wireless Network Signal Strength in Lunar Terrain
Torrado P., Pearson A., Klein J., Moscibroda A., Smith J. · ICASSP 2026
2025
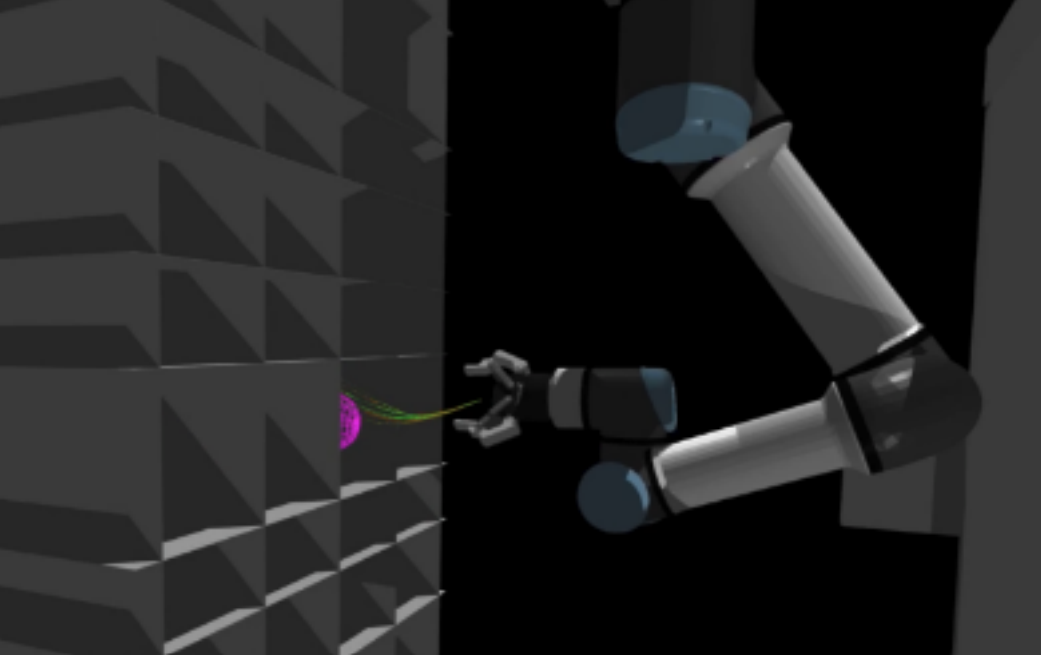
TetraGrip picking in clutter
TetraGrip: Sensor-Driven Multi-Suction Reactive Object Manipulation in Cluttered Scenes
Torrado P., Levin J., Grotz M., Smith J. · IROS 2025
2023
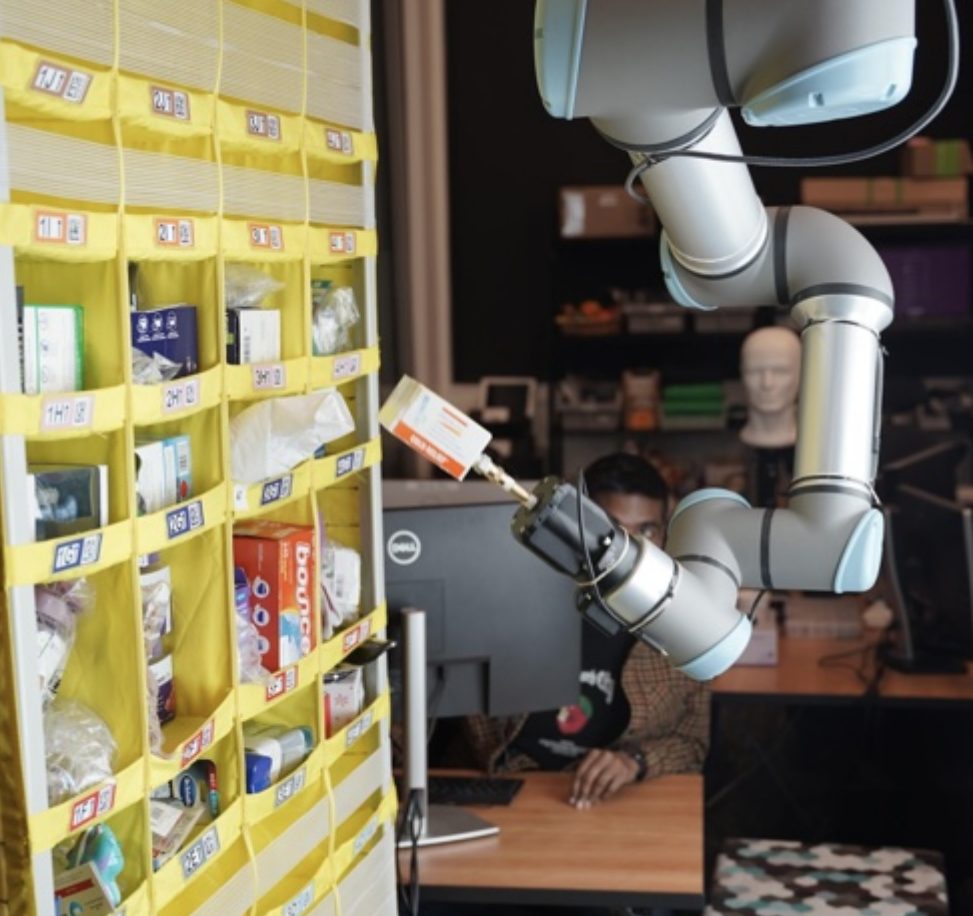
UR16e
Towards robustly picking unseen objects from densely packed shelves
Grotz M., Atar S., Li Y., Torrado P., et al. · RSS Workshop 2023
2023
roamingdtn
Roaming DTN: Integrating Unscheduled Nodes into Contact Plan Based DTN Networks
Ta D., Menon R., Taggart J., Tettamanti A., Feaser S., Torrado P., Smith J. · IEEE CCAAW 2023
2022
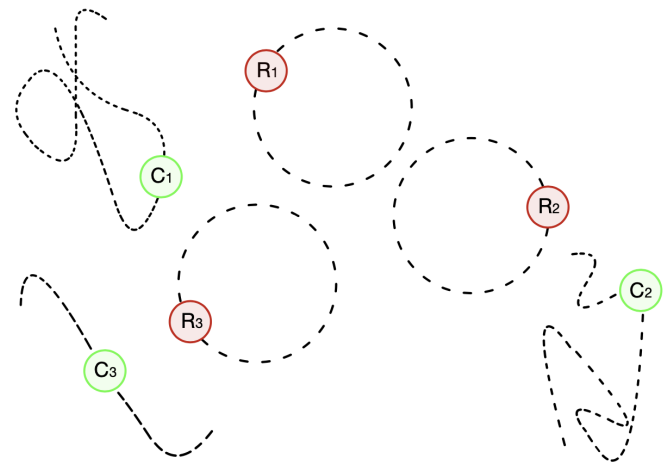
storm
Hierarchical Control Strategy for Moving a Robot Manipulator Between Small Containers
Torrado P., Yang B., Smith J. · Workshop IROS 2022
2016
asme
A practical approach to mitigate the excessive vibration of a piping system subjected to flow-induced excitation
Azizian R., Torrado P. · ASME Pressure Vessels and Piping Conference 2016

Projects and systems

HARDWARE
Custom suction gripper
3D-printed gripper with a Schmalz four-station SCTSi vacuum ejector, an Arduino, and range ToF sensors.
WIRELESS · SIMULATION
Deep RF raytracer
A custom raytracer for RF wireless signals, built for deep learning.
ROBOTS · FLEET
MuSHR fleet
Spearheaded the construction of twenty MuSHR robots.

Background

Before the PhD, a decade of licensed mechanical engineering practice on refinery and capital projects, and a stint developing historic residential and commercial property in New Orleans.